Gripper.
Teach by doing.
A handheld tool for teaching robots. In development.
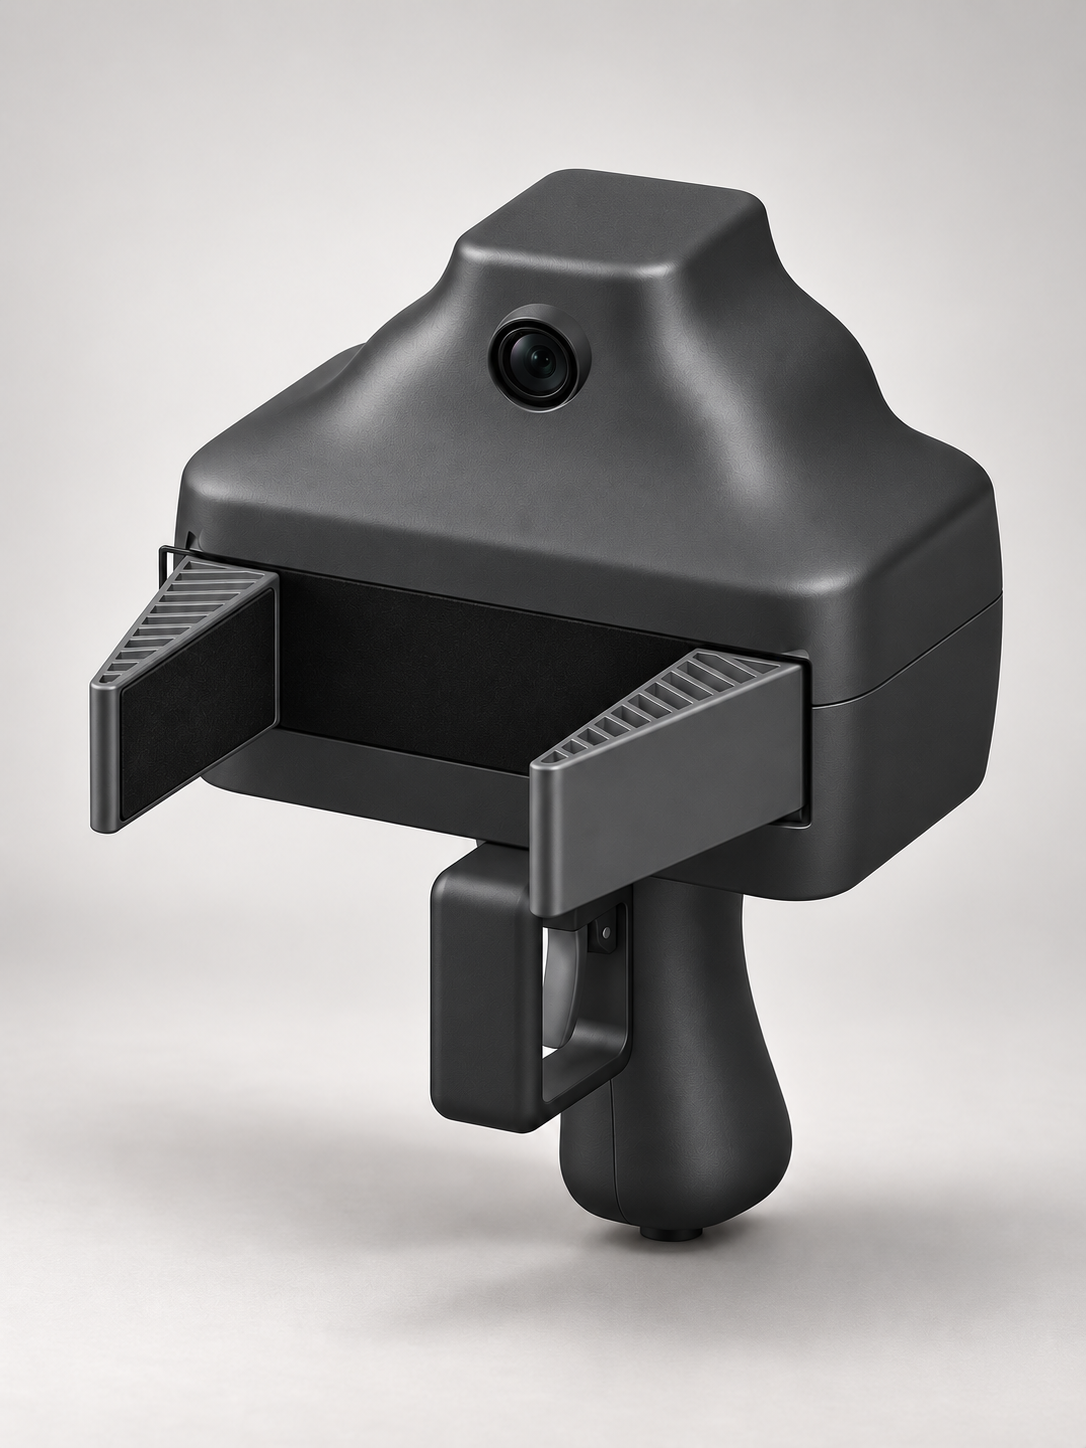
Hold the tool.
Show the task.
Guide the jaws with the trigger.
Demonstrate a pick, a placement or a packing task.
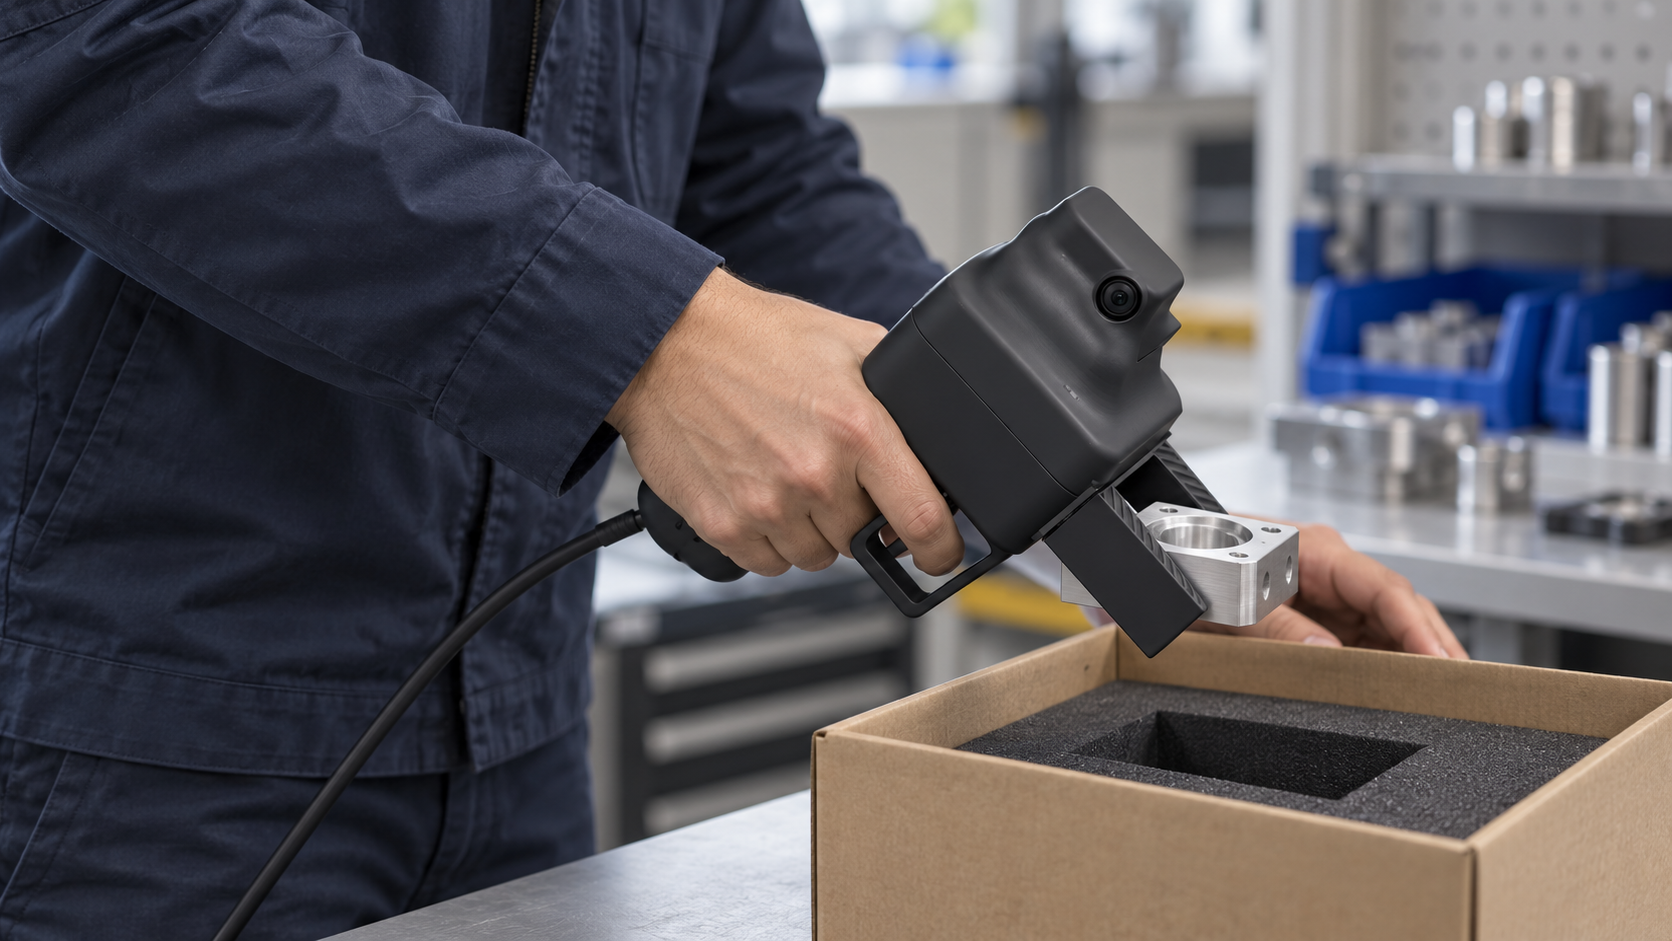
The work in front.
The mechanics inside.
A curved shell covers the drive and wiring. The ribbed fingers stay out front.
The handle and trigger are removable. A small lens sits above the jaws, integrated into the shell.
Take a closer look.
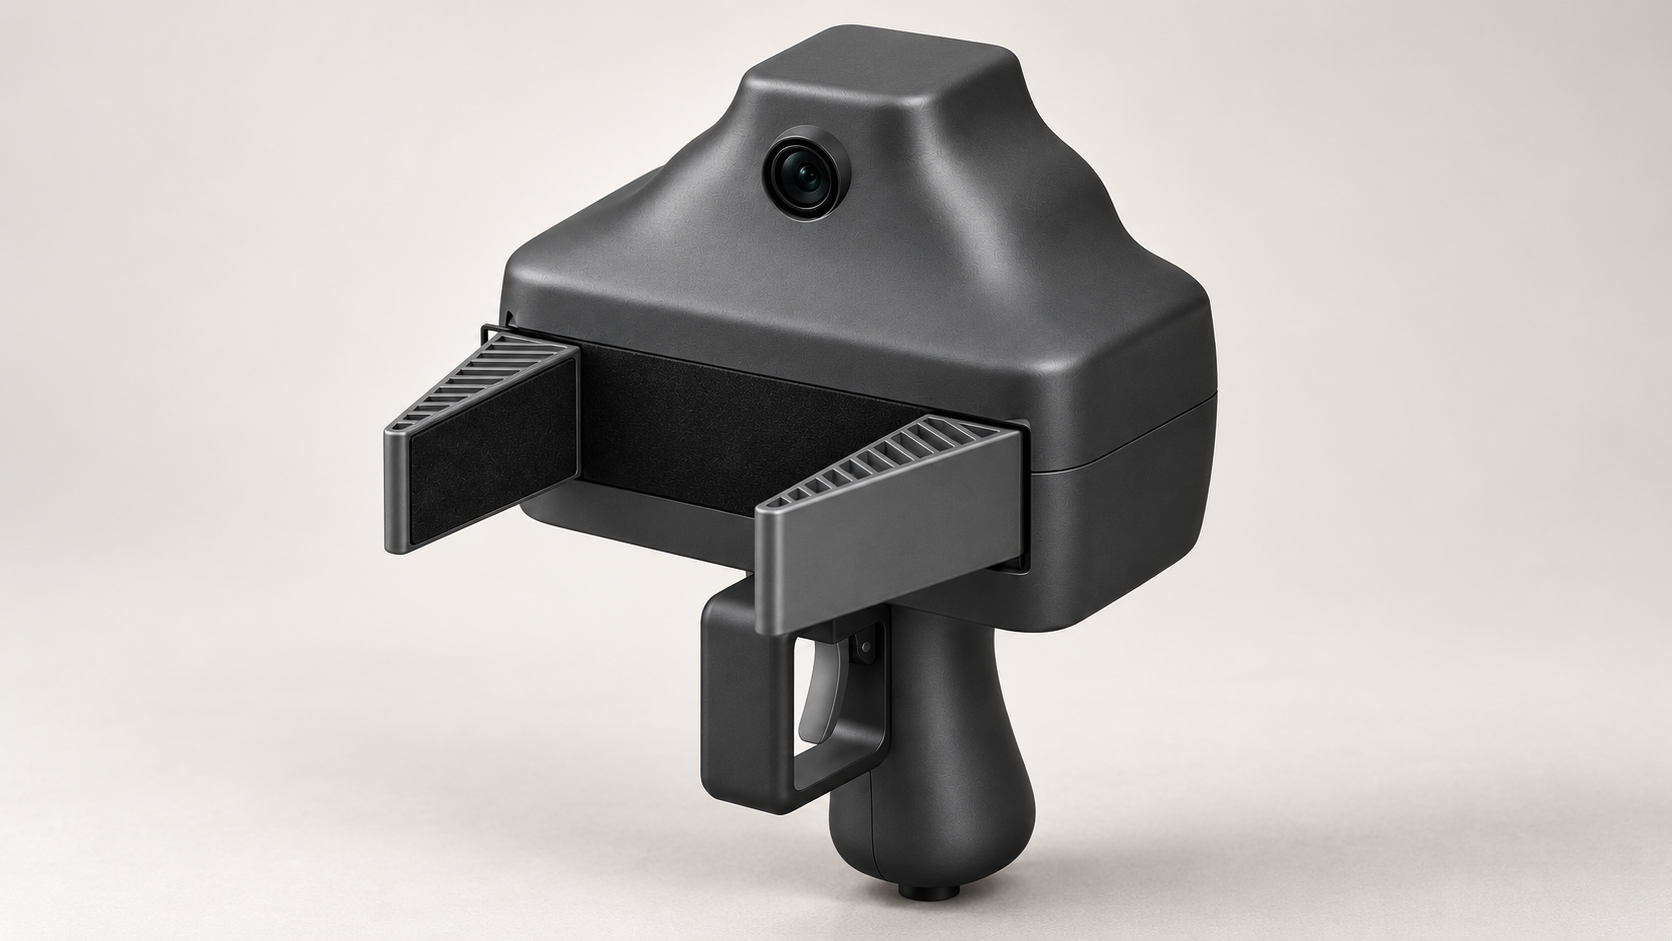
The complete handheld form.
Integrated camera.
Planned to record the work from the tool's viewpoint, using an external computer.
Forward jaws.
Intended to grip and place parts. The powered mechanism stays enclosed behind them.
Electrical trigger.
A planned electrical control for opening and closing the powered jaws.
Detachable handle.
The removable handle is intended for human demonstrations. The planned robot version would omit the handle and trigger.
The same gripper.
Human to robot.
The planned robot version uses the same gripper and camera, without the handle or trigger. Robot mounting and learning still need testing.